
The large robotic arm on the International Space Station has stopped working
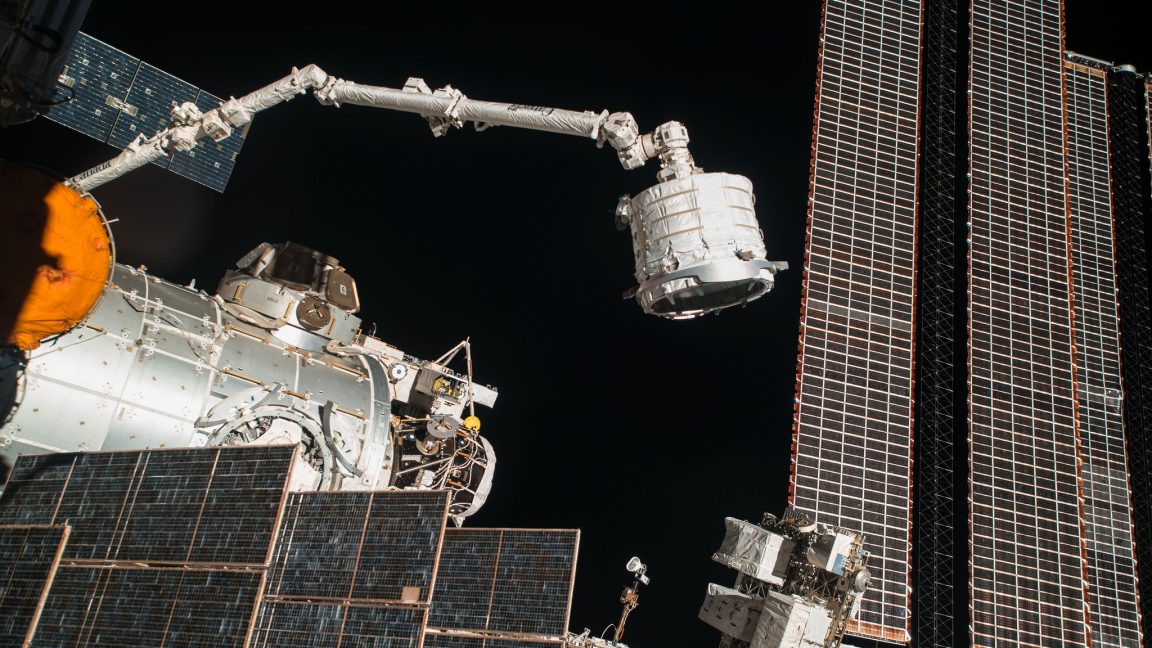
The International Space Station's primary robotic arm, Canadarm2, has encountered a significant operational failure following a routine maintenance maneuver. The 58-foot-long arm, which is capable of traversing the station's exterior like an inchworm, became unresponsive after a "walk-off" procedure. This maneuver involves detaching one end of the arm from its base and reattaching it to a different power and data port to relocate along the station's main truss. Currently, both the robotic arm and the mobile transporter that facilitates its movement are immobilized. Engineers are investigating the cause of the malfunction, which impacts the station's ability to perform external maintenance and cargo operations. The Canadarm2, a critical piece of infrastructure provided by the Canadian Space Agency, has been essential for station operations for years. NASA and its international partners are working to diagnose whether the issue stems from a software glitch or a mechanical failure in the mobile transporter system.
This is a summary. Read the full article at the original source:
Ars TechnicaRelated stories

Startup Star Catcher is preparing for a groundbreaking mission that aims to demonstrate the feasibility of wireless power transmission in orbit. The c…

The 'Lunar Terminator Paradox' explores a fascinating optical and physical phenomenon occurring at the moon's terminator line—the boundary between day…

Our world could be an advanced version of Game of Life, and in 10k years a megastructure will stand where the Moon and Earth are
The author proposes viewing our Universe as a complex chaotic system, mathematically similar to Conway's Game of Life. In this model, matter spontaneo…